Deep learning is rapidly transforming robotics. Foundation models - and especially LLMs - can interpret images, understand natural language instructions and make increasingly complex decisions, even writing code. These advances are fueling excitement about a future where robots operate autonomously in factories, warehouses and other real-world environments.
But it’s important to understand the right role for such systems in the automation stack; learning is only part of the technology required to make robotics practical and useful for the majority of manufacturing tasks.
In physical systems, the real challenge is not just deciding what to do at a high-level; it’s also executing motion exactly as intended, down to the last detail. Unlike software systems, mistakes in the physical world can damage equipment, halt production, or create safety risks.
While deep learning excels at perception and reasoning, it is inherently approximate, meaning errors can occur in ways that are difficult to predict or explain. And in robotics, those errors carry physical consequences that purely digital systems never risk.
Foundation models and other machine-learning systems work by generalizing from data. This approach has proven remarkably effective in a wide range of tasks involving perception and decision-making, but it is inherently approximate. Learning-based systems can - and do - inevitably generate errors that are difficult to predict or explain, and the only means to improve their reliability is to generate ever larger quantities of training data, without any sort of guarantee about how much, or which, data will be required, or when the system can eventually be trusted.
Differences in the Data
A simple analogy helps illustrate the difference between learning-based approaches and exact algorithms. Imagine replacing your spreadsheet with a system that usually adds and multiplies correctly—but occasionally produces slightly incorrect answers, without explanation. In many cases, that could be fine!
But for important business tasks like calculating salaries or filing taxes, few would find that trade-off acceptable, because exact arithmetic is both possible and necessary - indeed, it is already widely available. The same principle applies to robot motion. When exact solutions can be computed directly, approximation introduces risk without providing meaningful benefit.
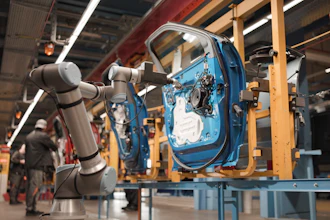
Any machine capable of moving quickly and exerting significant force—whether an industrial arm, an autonomous vehicle or a humanoid robot—can cause serious harm or material damage if it moves incorrectly. Unlike humans, robots are rigid, powerful and do not naturally absorb physical errors. A mistake that would result in a minor inconvenience for a person can damage equipment, destroy components or halt operations entirely when performed by a robot.
The consequences are not limited to safety. They are economic. When a human bumps into a conveyor or fixture, the result may be a brief interruption. When a robot makes the same mistake, the result is a damaged robot, a damaged product, damaged infrastructure, and a shut-down production line - costs that can exceed hundreds of thousands of dollars. In typical manufacturing use-cases, when a robot makes hundreds or thousands of motions a day, even a 0.01 percent collision rate will bring feasibility to a screeching halt.
Predicting the motion of a robot workcell correctly most of the time, to within a few inches, will never be sufficient. Exact solutions are mandatory.
For decades, roboticists have understood how to compute exact, collision-free motion using trustworthy methods that provide predictable and verifiable results, ensuring robots move safely and efficiently. But traditional implementations have struggled to operate at the speed and scale required for modern systems.
Generating high-performance motion plans often required extensive manual effort and long computation times, limiting flexibility and slowing deployment. In the absence of fast, scalable deterministic solutions, learning became the only practical alternative. Learning-based approaches were pursued not because approximation was inherently preferable, but because existing deterministic methods could not keep pace with the growing demands placed on robotic systems.
That limitation is now beginning to change. Advances in exact motion planning have made it possible to generate precise, reliable motion automatically and at speed. These systems already exist, and they are both reliable and fast – they are precise, performant, and industrial-quality software is ready for deployment (and has already been deployed) today.
The historical trade-off between precision and scalability is a thing of the past. Exact solutions can now be applied in contexts where approximation was previously the only viable option.
That does not diminish the importance of foundation models. On the contrary, their greatest impact in robotics is likely to come at higher levels of decision-making—determining what tasks a robot should perform, how it should adapt to changing environments and how it should coordinate with other systems.
The challenge is to integrate these capabilities with existing methods that guarantee precise and performant motion at the execution level. Foundation models will enable robots to understand and reason about the world in new ways. Exact motion planning will ensure those decisions can be executed reliably - never colliding, always meeting cycle time - in the physical world. The future of robotics will combine both approaches.
George Konidaris is the co-founder and Chief Scientific Advisor of Realtime Robotics. He is also a Professor of Computer Science at Brown.